OSU Engineers Test Locomotion Abilities of Two-Legged Robot
In a rolling, outdoor field, full of lumps, bumps and uneven terrain, researchers at Oregon State University last week successfully field-tested for the first time the locomotion abilities of a two-legged robot with technology that they believe heralds the running robots of the future.
The test demonstrated how their "ATRIAS" robot can move quite nicely, keep its balance and withstand mild blows from a bouncing rubber ball, while taking a walk in the grass, up and down hill, and over varying terrain at a normal walking speed of a little more than three miles per hour.
As a bipedal robot that was biologically inspired to mimic the spring-legged action of animals, the researchers said this is the closest a machine has yet come to resembling human locomotion.
The human-sized robot had six electric motors powered by a lithium polymer battery about the size of a half-gallon of milk, which is substantially smaller than the power packs of some other mobile robots. This is made possible by the energy efficiency of its elastic leg design and the energy retention that's natural to animal movement.
"Animals with legs sort of flow in the energy used, in which retained kinetic energy is just nudged by very efficient muscles and tendons to continue the movement once it has begun," said Jonathan Hurst, an Oregon State associate professor of mechanical engineering, and director of the Dynamic Robotics Laboratory in the OSU College of Engineering.
"That's part of what's unique about ATRIAS - not just that it can walk, and will eventually run - but that it's doing so with animal-inspired fluidity of motion that is so efficient," Hurst said. "This will ultimately allow a much wider range of robotic uses and potential than something which requires larger amounts of energy."
In these tests, the robot was tethered to a safety harness on a supporting frame that rolled along with it - not to supply energy or aid in walking, but just to help catch it if it fell, which it did a couple times due to sensor glitches. The goal was to prevent costly damage during the research and development.
"It already appears that ATRIAS is three times more energy-efficient than any other human-sized bipedal robots," said Christian Hubicki, an OSU postdoctoral scholar working with Hurst. "And this was the first time we've been able to show its abilities outside, in a far more challenging environment than anything in a laboratory.
"This is part of a continuous march toward running robots that are going to be useful and practical in the real world."
This work has been supported by an original $4.7 million, four-year grant from the Defense Advanced Research Projects Agency of the U.S. military. It has been done in collaboration with Jessy Grizzle at the University of Michigan and Hartmut Geyer at Carnegie Mellon University, and scientific work on the motion of animals was done with Monica Daley at the Royal Veterinary College, which guided the robot's development.
A key to progress with this new technology has been fundamental research on how animals move so effectively.
A one-year-old baby, or for that matter a strutting bird, can combine sensory input from nerves, vision, muscles and tendons to allow a level of locomotion that scientists are still working to emulate. Worth noting, however, is that the theoretical concept of "spring mass walking" developed less than a decade ago was on display last week in a working robot.
Near term goals, the researchers said, might be prosthetic limbs for people, or use of an exo-skeleton to assist people with muscular weakness. But robots that can move effectively over uneven terrain also open applications in the military, in disaster response, or any type of dangerous situation.
Featured Product
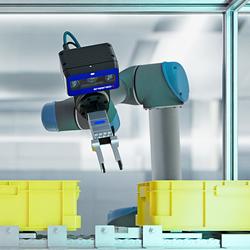
Nion: Next-level time-of-flight
The new Nion 3D camera advances Time-of-Flight (ToF) technology with exceptional resolution, speed, and industrial robustness. Designed for demanding applications such as logistics, warehousing, industrial automation, and robotics, Nion delivers high-resolution depth data with real-time performance for faster, safer, and more flexible operations. At its core is the 1.2-megapixel Time-of-Flight sensor AF0130 from onsemi's Hyperlux ID family, offering up to four times the resolution of conventional VGA-based ToF cameras and significantly higher data density. Active 940-nm laser illumination ensures accurate and stable measurements in low-light conditions, artificial lighting, and even direct sunlight. With an IP67-rated housing, Nion is built for reliable operation in dusty, wet, and thermally challenging industrial environments. A user-friendly API with IDS peak support and compliance with the GigE Vision standard enable fast integration and flexible deployment in high-resolution 3D applications. The Nion 3D camera is now available from IDS Imaging Development Systems.